

Foreign-object inspection inside returnable glass bottles
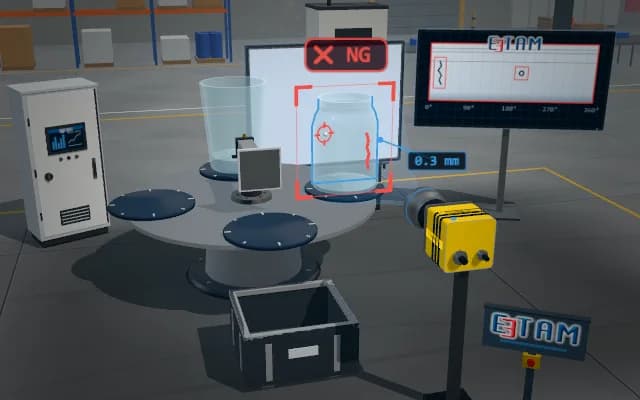
While the empty bottle is carried by side belts, its base is lit from below and a camera above looks in through the mouth to image the base. A dark blob in the image is flagged as a solid foreign object, a low-contrast ring as residual liquid; in both cases the bottle is rejected.
The result and blob area of every bottle are sent to the line PLC; a contaminated bottle is pushed into the reject bin. The stack light shows the station status, and the operator display shows the last base image and the blob area.

- 01 Infeed
- 02 Transfer
- 03 Acquire
- 04 Analyse
- 05 Decide
Washed empty bottles arrive at the station in single file.
- Objects found
- —
- Blob area
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
The camera looks through the narrow bottle mouth: the whole base is seen within a small angle and the sidewall darkens the image edge. Water droplets left after washing, the knurled base ring and the base dome also cast shadows; solid objects and pooled residual liquid must be told apart from them.
Solution approach
The base is lit from below with transmitted light: the glass appears bright, anything inside as a dark silhouette. A long-focal-length camera looks straight down the bottle axis and images the base disc the mouth allows. Dark blobs are classified by area and shape: a compact blob is a solid object, a low-contrast ring is residual liquid; knurling and dome are masked.
Process steps
- 01
Infeed
Washed empty bottles arrive at the station in single file.
- 02
Transfer
The trigger photo-sensor sees the bottle; side belts grip it by the body, leaving the base clear above the light.
- 03
Acquire
As the bottle arrives over the light, the base light strobes and the camera images the base through the mouth.
- 04
Analyse
The bright base image is searched for dark blobs; by area and shape they are classified as solid object or residual liquid.
- 05
Decide
Blob area is compared with the threshold; a contaminated bottle is pushed off.
Related applications


Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.