

Automatic robotic picking and traying of fasteners
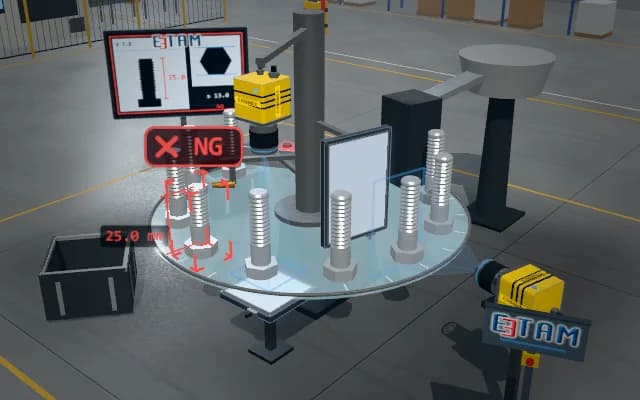
Bolts are scattered on a feeder plate lit from below. From the silhouettes a top camera tells pickable upright bolts from those lying flat and from a foreign part, and passes their positions to the robot. The robot places the bolts into the tray pockets in order and removes the foreign part.
Pick positions and orientations are passed to the robot; suitable bolts enter the tray and the foreign part is dropped in the reject bin. The display shows occupied-pocket count and the tower signals placement decisions.

- 01 Acquire
- 02 Locate
- 03 Pick
- 04 Place
- 05 Remove
The plate vibrates to spread the parts; the backlight strobes and an image is taken.
- Pick position X
- —
- Pick position Y
- —
- Placed
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
Overlapping or lying bolts are unsuitable for the gripper, and a different head type can enter the feeder. Located positions must map to robot coordinates and the correct tray pocket.
Solution approach
A plate lit from below produces dark silhouettes; the top camera captures after vibration stops. Head contour and posture identify pickable candidates; lying parts wait and a different head receives NG. Screen position and orientation marks become robot targets, and tray occupancy shows placement results.
Process steps
- 01
Acquire
The plate vibrates to spread the parts; the backlight strobes and an image is taken.
- 02
Locate
Upright, lying and foreign parts are told apart from the silhouettes; pick order is set.
- 03
Pick
The robot moves to the position given by the camera and grips the bolt by its shank.
- 04
Place
The bolt is set into the next free pocket of the tray.
- 05
Remove
The foreign part is taken off the plate and dropped into the reject bin.


Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.