

Flexible-cable endpoint tracking and robot-target updates
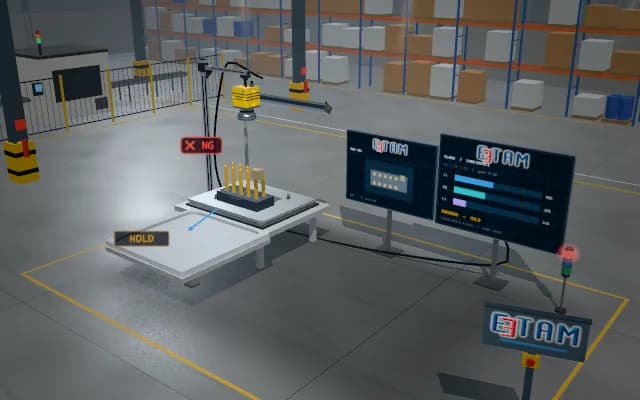
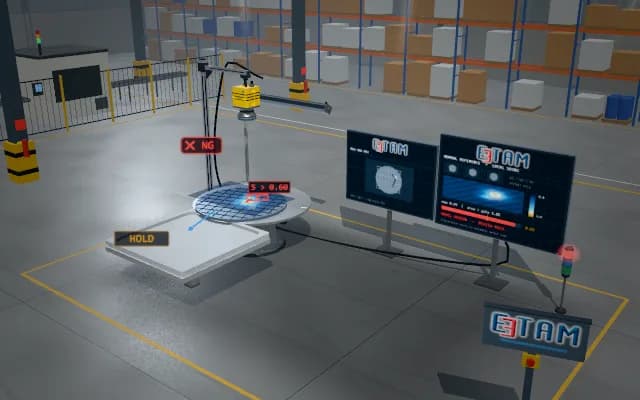
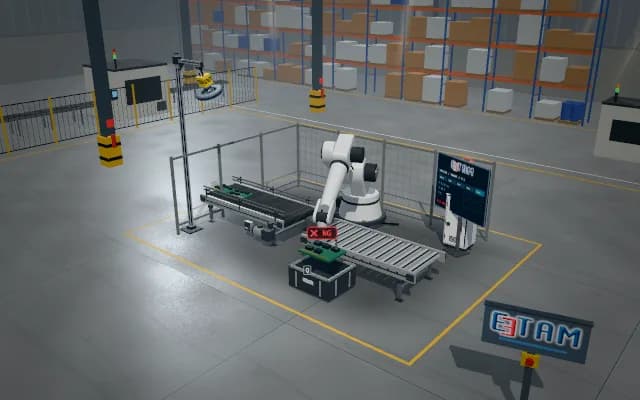
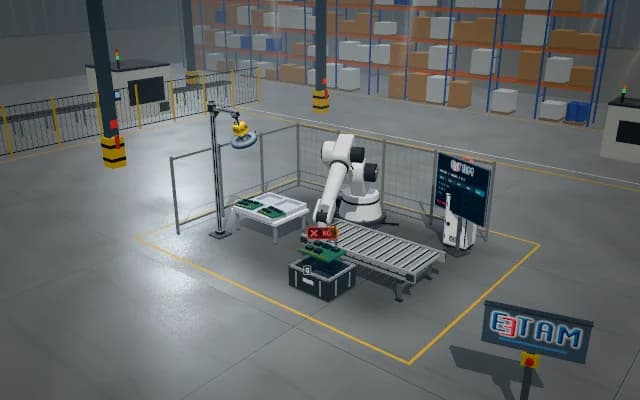
The current cable track and endpoint target are shown together. A visible verified endpoint allows the simulated pick; stale or insufficiently visible targets hold the motion command. Vision, identity and command states are animated as an illustrative simulation.
The current cable track and endpoint target are shown together. A visible verified endpoint allows the simulated pick; stale or insufficiently visible targets hold the motion command.

- 01 Frame
- 02 Track
- 03 Associate
- 04 Validate target
- 05 Allowed command and record
Items arrive and the initial frame and item context are established. Vision results are illustrative.
- Visible item tracks
- —
- Valid associations
- —
- Simulated command
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
A flexible cable bends during movement and its endpoints do not stay fixed. A target from an earlier image may be stale when the robot approaches; an occluded endpoint has no current pose.
Solution approach
Flexible-cable endpoints are relocalised during movement; the robot target uses current image evidence and holds when an endpoint is occluded.
Process steps
- 01
Frame
Items arrive and the initial frame and item context are established. Vision results are illustrative.
- 02
Track
Each visible item receives a separate track contour; the first contour is the annotated track component.
- 03
Associate
Flexible-cable endpoints are relocalised during movement; the robot target uses current image evidence and holds when an endpoint is occluded.
- 04
Validate target
The track is checked against its event record and uncertain association enters HOLD. No physical command has been applied in this phase.
- 05
Allowed command and record
Only a validated target enters a simulated robot pick; the other cycle has no command and keeps the candidate on hold.
Related applications




Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.