

Robotic part feeding from pocket trays to a conveyor
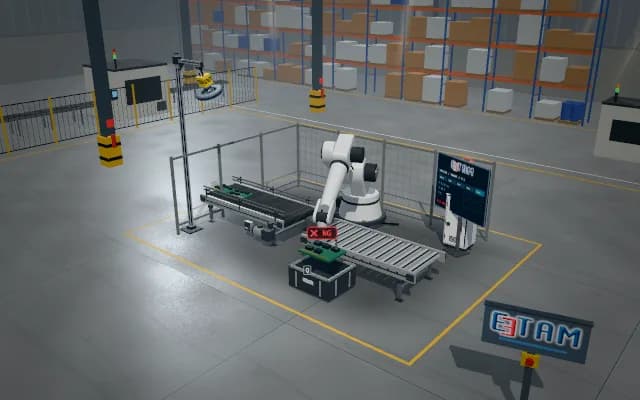
Only an occupied, orientation-verified pocket is fed. Source, grip and destination states share one simulated cycle record; empty pockets or wrong orientation enter a controlled hold. Calibration, grip and PLC sequence are animated as an illustrative simulation.
Only an occupied, orientation-verified pocket is fed. Source, grip and destination states share one simulated cycle record; empty pockets or wrong orientation enter a controlled hold.
- 01 Image and source
- 02 Pose and plan
- 03 Grip and lift
- 04 Transfer
- 05 Release and final check
Capture the tray and board; distinguish the occupied pocket from the tray reference.
- Illustrative pose offset
- —
- Illustrative grip confirmation
- —
- Completed transfers
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
A PCB can occupy the wrong tray pocket, face the wrong way or shift in its nest. Picking by pocket sequence alone can grasp an empty slot; presence and orientation need verification before feeding.
Solution approach
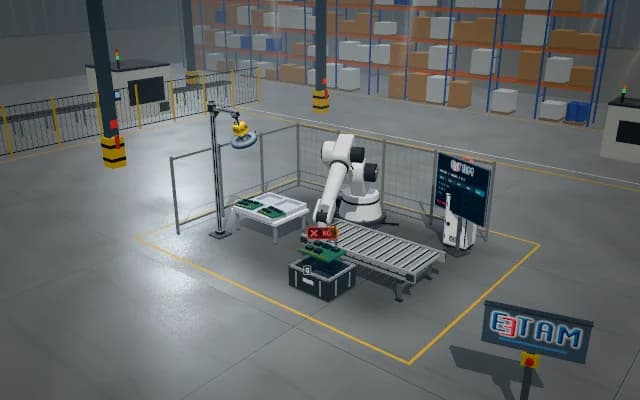
An overhead image locates the tray reference and occupied pocket; PCB pose transforms into robot coordinates. The gripper picks, lifts, transfers and lowers the board onto the infeed. A final image checks placement on the belt and clearance of the source pocket.
Process steps
- 01
Image and source
Capture the tray and board; distinguish the occupied pocket from the tray reference.
- 02
Pose and plan
Verify board orientation and pocket pose; check that the belt infeed is clear in the simulated sequence.
- 03
Grip and lift
The gripper approaches the board and receives grip confirmation; lift clear of the tray.
- 04
Transfer
Carry the board attached to the gripper towards the infeed; the source pocket remains empty.
- 05
Release and final check
Lower and release the board onto the belt; placement confirmation completes the feed record.
Related applications




Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.