

Applying robot offsets from vision-located fixture shifts
The current fixture offset and placed bracket share one cycle record. A missing reference or occupied nest prevents blind continuation towards the nominal pose. Vision, robot and PLC states are an illustrative solution concept.
The current fixture offset and placed bracket share one cycle record. A missing reference or occupied nest prevents blind continuation towards the nominal pose.

- 01 Image and reference
- 02 Pose and evaluation
- 03 Grip and lift
- 04 Controlled transfer
- 05 Final check and record
Locate the bracket and target-fixture reference in separate image contexts.
- Illustrative pose offset
- —
- Illustrative grip confirmation
- —
- Completed transfers
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
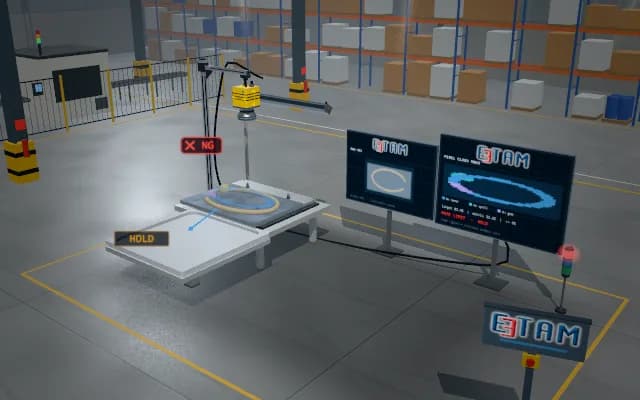
A shifted assembly fixture can make a fixed robot target approach the wrong nest. Locate part pose and current fixture position separately; an old offset must not carry into a new cycle.
Solution approach
Locate the part and fixture reference in separate image regions. Associate the fixture difference from its taught reference with the placement target in robot coordinates. Grip, lift and carry the bracket to the offset target; check final seating against the reference and current fixture context.
Process steps
- 01
Image and reference
Locate the bracket and target-fixture reference in separate image contexts.
- 02
Pose and evaluation
Associate the current fixture difference with placement; distinguish nominal and offset poses.
- 03
Grip and lift
Grip and lift the bracket from its source nest.
- 04
Controlled transfer
Carry the bracket above the fixture target with its current offset applied.
- 05
Final check and record
Lower and release the bracket; check seating and reference context in the final image.
Related applications





Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.