

Part-presence and grip verification before transfer
Closure, part presence and destination confirmation share one transfer record. Empty or uncertain gripping prevents completion and requires another check. Vision, robot and PLC states are an illustrative solution concept.
Closure, part presence and destination confirmation share one transfer record. Empty or uncertain gripping prevents completion and requires another check.

- 01 Image and reference
- 02 Pose and evaluation
- 03 Grip and lift
- 04 Controlled transfer
- 05 Final check and record
Image the source shaft and define the gripping region.
- Illustrative pose offset
- —
- Illustrative grip confirmation
- —
- Completed transfers
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
Closed fingers alone do not prove that a shaft was gripped correctly. Empty closure, wrong height or a shifted part can invalidate transfer; follow image evidence and gripper state together.
Solution approach
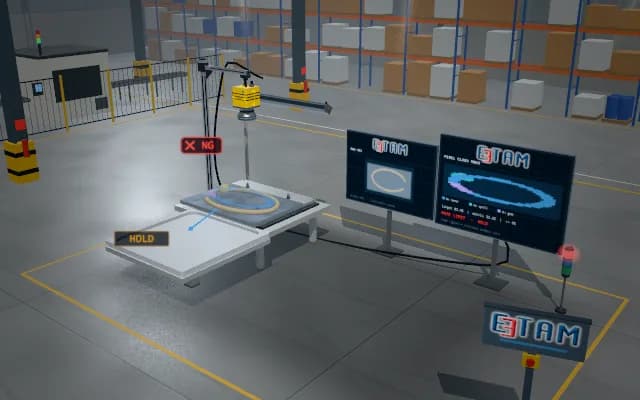
Locate the source shaft and represent approach and gripper closure. Associate image-based part presence and position with a separate grip-state signal. Lift and carry to the destination; verify target presence after release. The percentage display is not a real force measurement.
Process steps
- 01
Image and reference
Image the source shaft and define the gripping region.
- 02
Pose and evaluation
Associate shaft pose with gripper approach; separate image and signal confirmations.
- 03
Grip and lift
Close the gripper, confirm part presence and lift the shaft from the source.
- 04
Controlled transfer
Carry the verified shaft attached to the gripper while following grip state.
- 05
Final check and record
Lower and release the shaft; destination-presence confirmation completes the transfer record.
Related applications





Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.