

Moving-belt robotic picking with posture-specific calibration
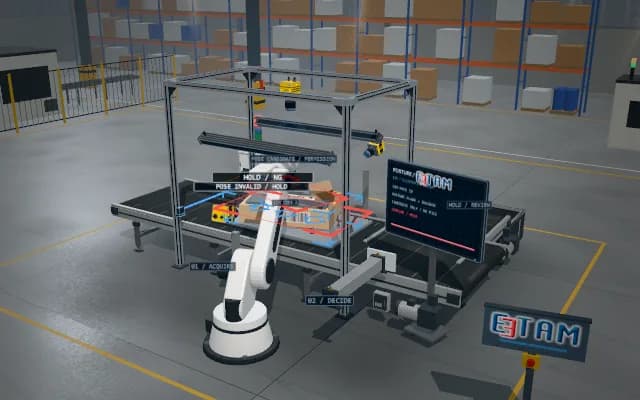
Recycling packs can arrive on a belt at different angles and postures. A position computed on one ground plane can shift when pack height changes; overlapping or late packs also fail to provide a reliable picking target.
Proposed output: posture-dependent pick pose, remaining window and placement evidence. Plane selection is an added design option; piled feed requires evaluation of extra height measurement or singulation.
- 01 Presentation
- 02 Trigger and reference
- 03 Image / profile
- 04 Decision
- 05 Evidence and PLC
Locate the pack with an identity
- Sample record
- —
- Pose and picking-window validity
- —
- Acquisition progress
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Solution approach
Locate the pack in the top view, classify its posture and select the validated calibration plane for that posture. Keep identity, angle and encoder stamp with one target. Hold overlapping, invalid-posture or expired targets. Re-image aligned placement on the second belt.
Process steps
- 01
Presentation
Locate the pack with an identity
- 02
Trigger and reference
Select the posture-specific plane
- 03
Image / profile
Track the pick target with the encoder
- 04
Decision
Pick within a valid window
- 05
Evidence and PLC
Verify placement on the second belt
Related applications





Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.