

Robotic picking and mounting of counterweights from stacks
Dark counterweights on a pallet are located by shape and size in a 3D image. The robot picks a suitable part, orients it on the conveyor and places it at the mounting point on the outer drum; a wrong-size part is excluded from selection.
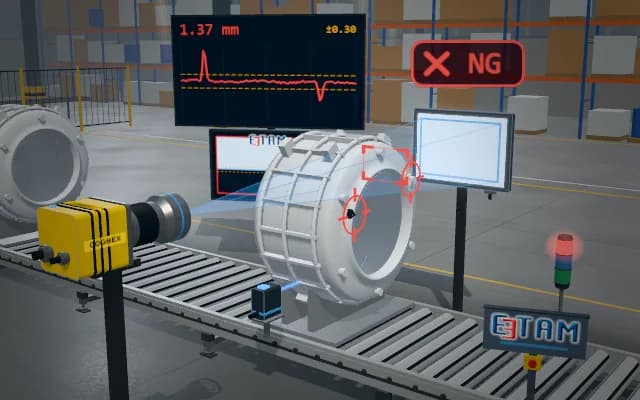
Part size, orientation and pick pose are sent to robot control. A suitable weight is moved to assembly; a size mismatch is shown on the display and stack light and excluded from selection.
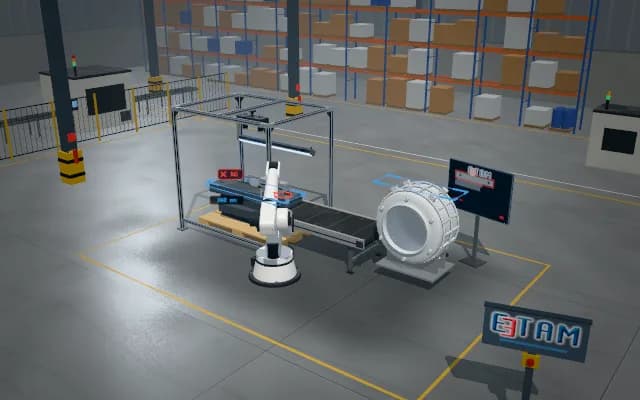
- 01 Position
- 02 Acquire
- 03 Analyse
- 04 Decide
The pallet and drum assembly fixture stop at the station.
- Part length
- —
- Length difference
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
Dark concrete or cast surfaces return little light; parts occlude one another. Different sizes with similar contours and reversed weights may occur in the same stack.
Solution approach
Visible surfaces and hole patterns in the overhead 3D image are matched to a geometric template. Under controlled lighting suited to dark surfaces, size, orientation and gripping clearance are assessed; the pose of an accessible part matching the required size is sent to the robot.
Process steps
- 01
Position
The pallet and drum assembly fixture stop at the station.
- 02
Acquire
The overhead camera scans the visible stack surfaces in 3D.
- 03
Analyse
Size and orientation are compared with the template; a suitable gripping pose is located.
- 04
Decide
A suitable weight is oriented and mounted; a wrong-size weight is not picked.
Related applications


Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.