

Robotic 3D pick & place assembly of dishwasher insulation material
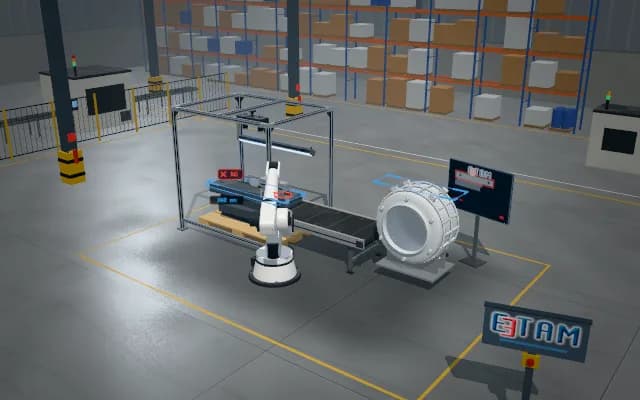
A 3D scan finds the position, angle and height of the flexible insulation pad on top of the stack. The robot picks the pad at these coordinates with a vacuum gripper, corrects the angle and sets it on the tub; a camera then verifies where the pad edges lie and the robot corrects the pad if it is off.
Pad centre, angle and stack height go to the robot controller as pick coordinates; if the edge offset is out of tolerance the robot makes a correction move, the result is written to the tub record and the stack light shows the state.

- 01 3D scan
- 02 Pose
- 03 Pick
- 04 Place
- 05 Verify
The laser line sweeps the top of the stack and builds a point cloud of the top pad.
- Pad angle
- —
- Stack height
- —
- Edge offset
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
The insulation pad is flexible and porous; in the stack every pad sits shifted and skewed relative to the one below, and its top surface is wavy. A fixed pick point grips the pad in the wrong place; the pad sags in transfer and lands on the tub out of tolerance.
Solution approach
A 3D laser profile sensor on a post scans the top of the stack and builds a point cloud of the top pad; centre, angle and stack height are computed from it and sent to the robot. The robot turns the vacuum gripper to that angle, picks the pad and sets it on the tub; a ring-lit camera measures the pad edges against the tub edges, and if the offset is large the robot corrects the pad and re-checks.
Process steps
- 01
3D scan
The laser line sweeps the top of the stack and builds a point cloud of the top pad.
- 02
Pose
Centre, angle and height of the pad are computed from the cloud and sent to the robot.
- 03
Pick
The robot turns the gripper to the measured angle and picks the pad by vacuum.
- 04
Place
The angle is corrected on the way and the pad is set down on top of the tub.
- 05
Verify
The robot clears the view and a camera measures the pad edges against the tub edges. If there is an offset the robot corrects the pad and the measurement is repeated.
Related applications




Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.