

3D robot guidance for inner and outer drum assembly of washing machines
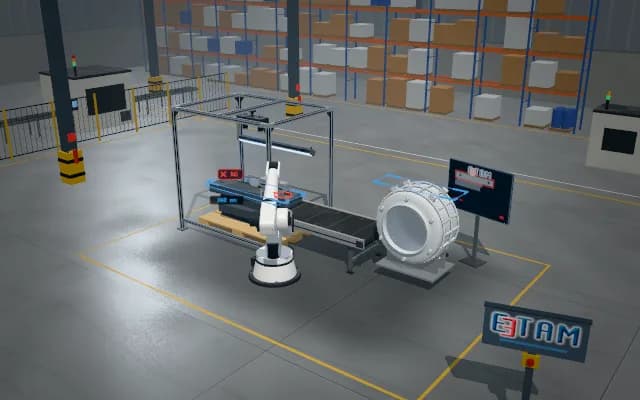
While the outer drum is held in a fixture, the robot brings the inner drum to the assembly opening. Both cylinder axes are located in the 3D image; position and angle offsets are sent to the robot, and insertion is stopped if alignment is unsuitable.
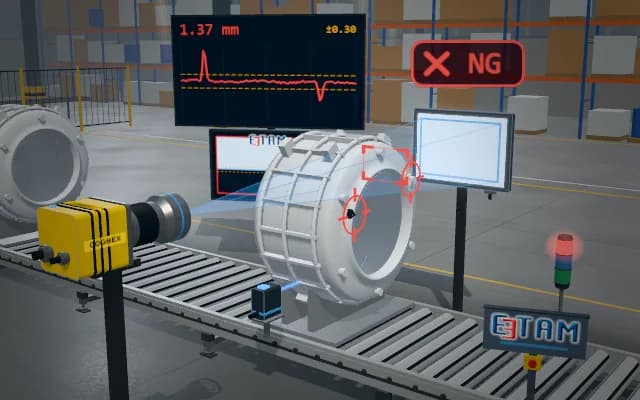
Position and angle offsets are sent to robot control; assembly proceeds with suitable alignment. Outside the limit the robot waits, and the axes and deviation appear on the operator display.

- 01 Position
- 02 Acquire
- 03 Analyse
- 04 Decide
The robot brings the inner drum in front of the fixture-held outer drum.
- Axis offset
- —
- Axis angle difference
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
The metal inner drum and plastic outer tub reflect differently; the fixture and gripper hide some edges. A small axis or angle difference can cause jamming during insertion.
Solution approach
An oblique 3D camera images both openings in the same volume. Geometric models are fitted to the visible rims and cylinder surfaces to locate their axes; translation and angle differences are sent to the robot as corrections. A final alignment limit enables insertion.
Process steps
- 01
Position
The robot brings the inner drum in front of the fixture-held outer drum.
- 02
Acquire
The 3D camera images both rims and cylinder surfaces.
- 03
Analyse
Cylinder axes are matched; position and angle corrections are calculated for the robot.
- 04
Decide
The drum is inserted with suitable alignment; the robot waits for an axis outside the limit.
Related applications




Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.