

Wheel recognition and final inspection
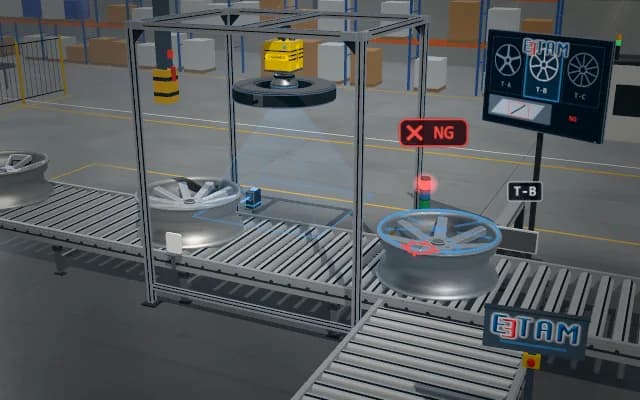
As mixed wheels pass under a ring-lit camera, an AI model recognises the wheel type from its spoke pattern and selects the inspection plan for that type. The face is scanned for cosmetic defects in the same image; a defective wheel is removed from the line.
The type code and surface result are sent to the wheel record and line control. A wheel with a scratch is pushed onto the side lane; the operator display shows the selected type and defect region.
- 01 Acquire
- 02 Recognise
- 03 Surface check
- 04 Decide
The photo-sensor sees the wheel; the ring light strobes and the face is captured.
- Wheel type
- —
- Spoke count
- —
- Surface defects
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
Spoke layout and coating tone vary by wheel type. Bright spokes reflect their surroundings; the inspection plan must first match the correct wheel so type differences are not treated as surface defects.
Solution approach
An overhead camera images the face under a wide ring light that illuminates the spokes evenly and without shadows; a photo-sensor synchronises acquisition with part passage. An AI model selects the type from its spoke signature, then scans the surface regions for that type; the scratch region is marked on the part and in an enlarged display image.
Process steps
- 01
Acquire
The photo-sensor sees the wheel; the ring light strobes and the face is captured.
- 02
Recognise
The AI model determines the wheel type from spoke count and layout.
- 03
Surface check
The face is scanned for scratches and paint flaws against the recognised type reference.
- 04
Decide
Type code and surface result are written to the wheel record and routing is set.
Related applications





Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.