

Robotic wheel marking system
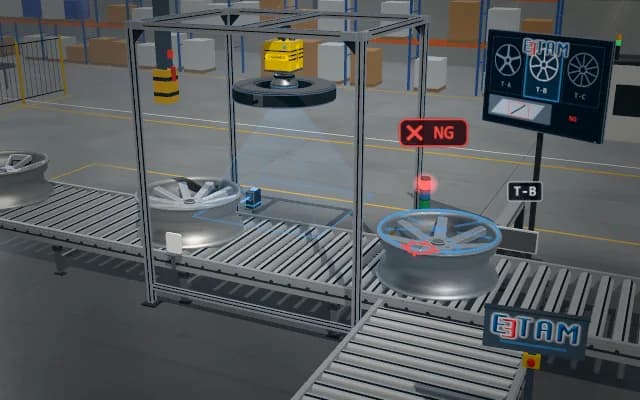
The wheel arrives at a random angle. The camera locates the valve hole, measures wheel orientation and passes the marking position to the robot, which writes the code there with a laser head. The same camera then reads the code to verify the mark.
The target calculated from the valve reference is transferred as a robot offset. The decoded code and verification result are written to the wheel record; an incomplete code is indicated on the operator display and stack light.

- 01 Positioning
- 02 Orientation
- 03 Marking
- 04 Verification
The wheel arrives on the belt and stops under the camera.
- Valve angle
- —
- Code read
- —
- Code grade
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
The wheel arrives at a different angle each time, so the spoke that must carry the code changes position. A small code on a bright surface can have low contrast; correct placement and readability must be verified separately.
Solution approach
An overhead camera locates the valve hole under ring illumination and calculates wheel angle. The marking target is transferred to the robot from this reference; after laser marking the robot withdraws, and a second image locates the code region to check content and readability together.
Process steps
- 01
Positioning
The wheel arrives on the belt and stops under the camera.
- 02
Orientation
The valve hole is located; wheel angle and marking position are calculated.
- 03
Marking
The robot moves over the calculated spoke and the laser head writes the code.
- 04
Verification
The camera reads the marked code; content and readability grade are checked.
Related applications





Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.