

Robotic silicone bead inspection on the oil pan cover
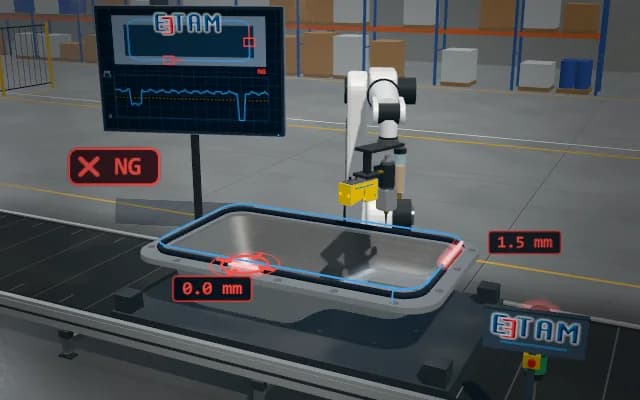
While the robot lays the silicone bead along the oil pan flange, a laser profile sensor directly behind the nozzle measures the bead cross-section. Width and continuity are tracked along the path; a thin or interrupted section is flagged with its position.
The width profile and defect positions are written to the oil pan record. The flange map on the operator display shows the affected sections; a decision is sent to line control and status to the stack light.
- 01 Positioning
- 02 Dispense
- 03 In-line gauging
- 04 Decide
The oil pan arrives on its pallet; the robot moves to the start point on the flange.
- Bead width
- —
- Narrowest
- —
- Gap length
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
Dark, glossy silicone is hard to separate from the reflections of the machined flange in a plain image. The bead can thin where nozzle speed changes at corners, and short gaps are easily missed in an overall view.
Solution approach
A profile sensor trailing the robot nozzle projects its laser line across the bead path; because the measurement relies on height rather than colour contrast, the dark bead is separated from the flange by its cross-section profile. Width is extracted relative to the flange base; sections are mapped to path position so thinning and gaps appear both on the part and in the on-screen map.
Process steps
- 01
Positioning
The oil pan arrives on its pallet; the robot moves to the start point on the flange.
- 02
Dispense
The nozzle lays a closed silicone bead along the flange.
- 03
In-line gauging
The laser line trailing the nozzle measures bead width section by section.
- 04
Decide
The width profile is compared with the lower limit and gap length is calculated.
Related applications





Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.