

Fixture-based traceable part handoff between two robots
Record two completed simulated transfers and an intermediate-fixture event for one bracket. Uncertain ownership, intermediate presence or destination confirmation holds handoff completion. Line, robot and PLC phases are animated as an illustrative simulation.
Record two completed simulated transfers and an intermediate-fixture event for one bracket. Uncertain ownership, intermediate presence or destination confirmation holds handoff completion.
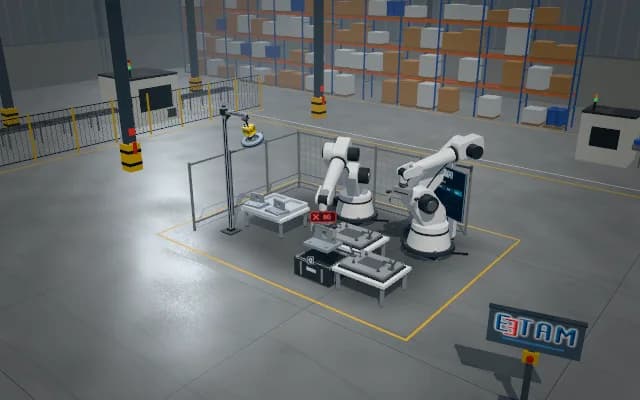
- 01 Line and item image
- 02 Target and line permission
- 03 Grip and lift
- 04 Transfer across the line
- 05 Receipt and final check
Show bracket identity, initial source and shared intermediate-nest context.
- Illustrative pose offset
- —
- Illustrative grip confirmation
- —
- Completed transfers
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
Two robots can confuse item identity and physical ownership during handoff. A second pick before release confirmation or new feeding into an occupied shared nest creates a process conflict; fixture-mediated handoff must remain visible.
Solution approach
Associate bracket identity with the first source and follow shared-fixture and final-buffer readiness separately. The first robot grips, transfers and releases into the intermediate nest. The second robot picks the released item and carries it to the outfeed; retain both picks and receipts in one item chain.
Process steps
- 01
Line and item image
Show bracket identity, initial source and shared intermediate-nest context.
- 02
Target and line permission
Associate intermediate-fixture and final-buffer readiness with separate transfer targets.
- 03
Grip and lift
The first robot grips and lifts the bracket from the source.
- 04
Transfer across the line
The first robot releases into the intermediate nest; the second picks the confirmed bracket and carries it to the outfeed.
- 05
Receipt and final check
The second robot releases at the final destination; link the intermediate event and both completed transfers to one item.
Related applications





Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.