

Re-imaging and controlled re-picking after a failed grip
Retain first attempt and re-imaging as separate events. Only a current target with grip confirmation completes the simulated re-pick; no unbounded automatic retry is represented. Vision, robot and PLC states are an illustrative solution concept.
Retain first attempt and re-imaging as separate events. Only a current target with grip confirmation completes the simulated re-pick; no unbounded automatic retry is represented.
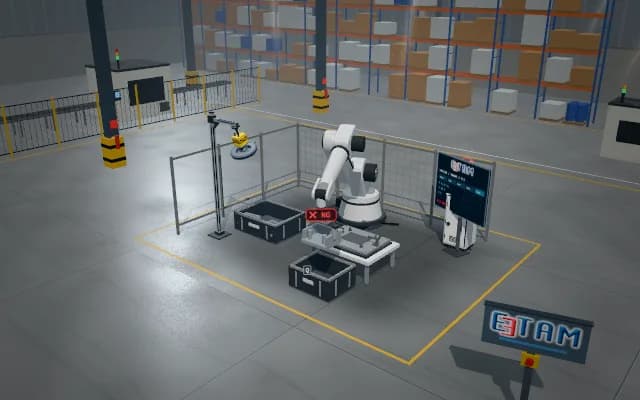
- 01 Image and reference
- 02 Pose and evaluation
- 03 Grip and lift
- 04 Controlled transfer
- 05 Final check and record
Show the source-part image and first-grip event context.
- Illustrative pose offset
- —
- Illustrative grip confirmation
- —
- Completed transfers
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
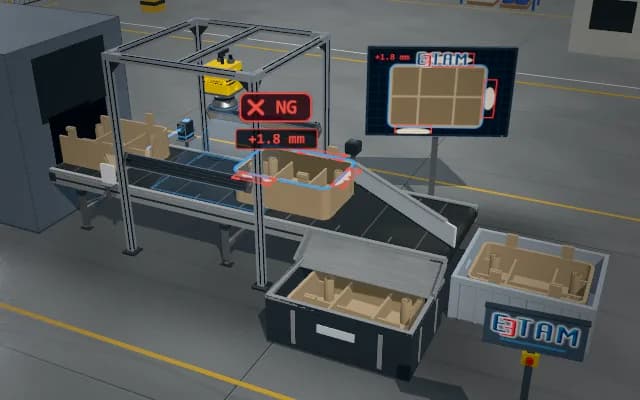
A failed first grip can shift a plastic part at the source. Reusing its earlier pose can repeat the failure; another attempt needs a current image, grip confirmation and bounded process sequence.
Solution approach
Compare first-grip state with source presence and hold the previous target after failure. Show a current pose candidate from a new image and represent the re-pick sequence. Grip, lift, carry and release at the destination; uncertainty holds completion permission.
Process steps
- 01
Image and reference
Show the source-part image and first-grip event context.
- 02
Pose and evaluation
Hold the old target after failure; re-imaging establishes a current candidate pose.
- 03
Grip and lift
Represent controlled re-gripping and lifting at the current candidate.
- 04
Controlled transfer
Carry the verified part to the destination; retain first attempt and new event separately.
- 05
Final check and record
Release and final-presence confirmation complete the re-pick; uncertainty stays under review.
Related applications



Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.