

Layer and robot-target association on mixed-carton pallets
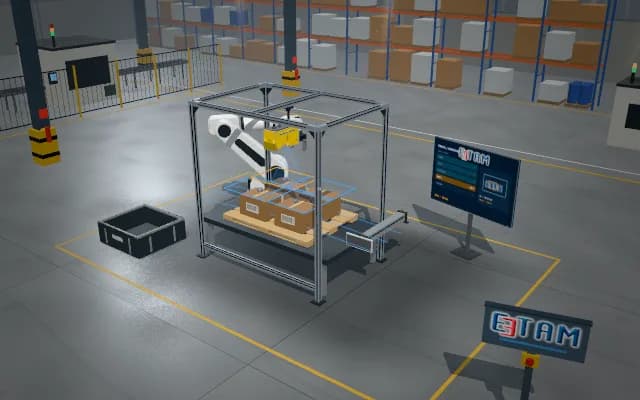
Carton layer and target identity link to a simulated robot path. A valid candidate is picked; an uncertain layer or colliding target stays on hold for verification. Vision, identity and command states are animated as an illustrative simulation.
Carton layer and target identity link to a simulated robot path. A valid candidate is picked; an uncertain layer or colliding target stays on hold for verification.
- 01 Frame
- 02 Track
- 03 Associate
- 04 Validate target
- 05 Allowed command and record
Items arrive and the initial frame and item context are established. Vision results are illustrative.
- Visible item tracks
- —
- Valid associations
- —
- Simulated command
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
Mixed cartons create different pallet heights and edge arrangements. A target confused with a neighbouring carton can send the robot to the wrong layer or an occluded face.
Solution approach
Carton layers, visible edges and robot targets are associated; a colliding target is held while a controlled pick path is shown.
Process steps
- 01
Frame
Items arrive and the initial frame and item context are established. Vision results are illustrative.
- 02
Track
Each visible item receives a separate track contour; the first contour is the annotated track component.
- 03
Associate
Carton layers, visible edges and robot targets are associated; a colliding target is held while a controlled pick path is shown.
- 04
Validate target
The track is checked against its event record and uncertain association enters HOLD. No physical command has been applied in this phase.
- 05
Allowed command and record
Only a validated target enters a simulated robot pick; the other cycle has no command and keeps the candidate on hold.
Related applications

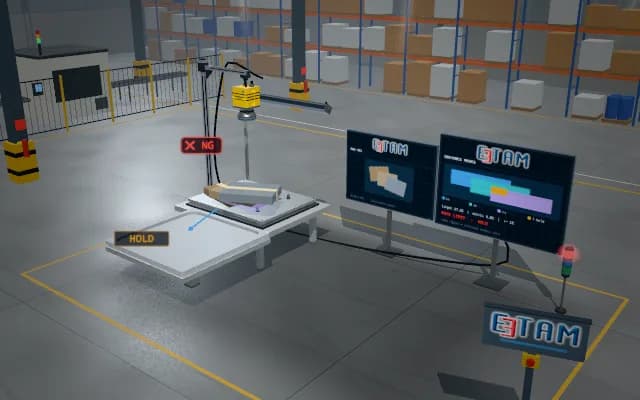
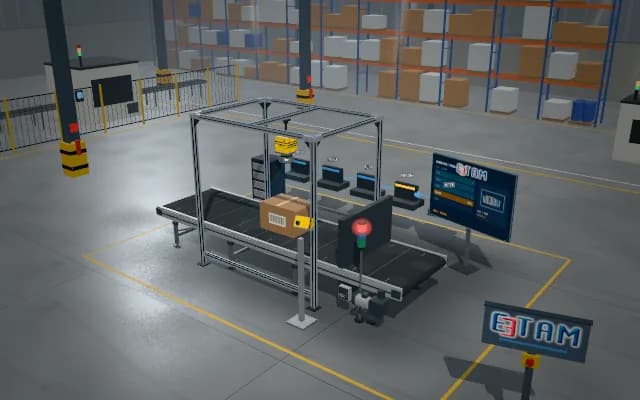

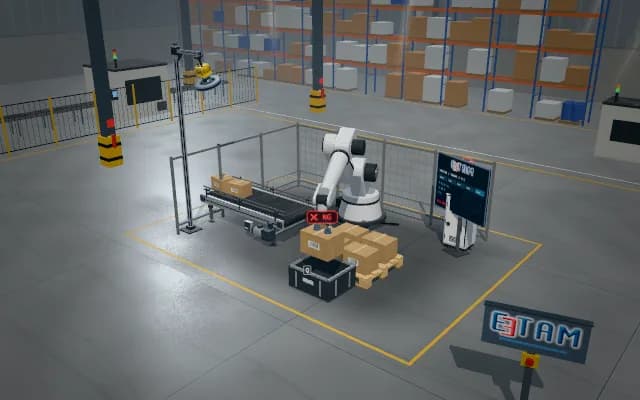


Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.