

Incremental robot alignment using visual feedback
Incremental alignment and placement share one target record. Stale or insufficiently visible images hold further correction permission; displayed values are illustrative. Vision, robot and PLC states are an illustrative solution concept.
Incremental alignment and placement share one target record. Stale or insufficiently visible images hold further correction permission; displayed values are illustrative.

- 01 Image and reference
- 02 Pose and evaluation
- 03 Grip and lift
- 04 Controlled transfer
- 05 Final check and record
Image the connector and target reference; establish the initial pose offset.
- Illustrative pose offset
- —
- Illustrative grip confirmation
- —
- Completed transfers
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
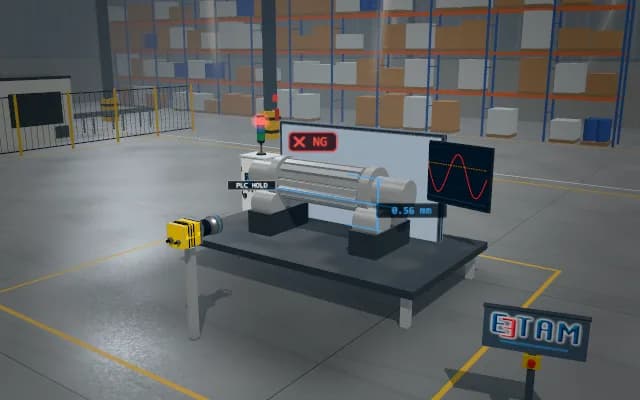
A residual offset during connector approach can affect final placement. An initial target from one image may be insufficient; distinguish the current image difference from the controlled incremental-motion decision.
Solution approach
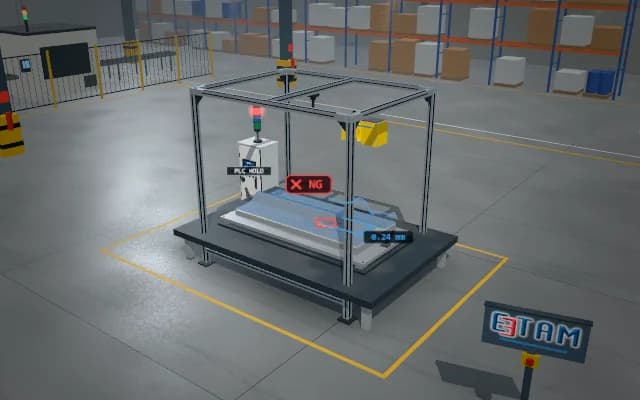
Associate the connector and target reference in the image; represent residual pose offset and incremental correction. Keep current image context separate from motion decisions. Grip the connector, approach the destination under sequence control and release; check seating. No live servo loop is executed.
Process steps
- 01
Image and reference
Image the connector and target reference; establish the initial pose offset.
- 02
Pose and evaluation
Show incremental correction from the image difference; no live servo calculation runs.
- 03
Grip and lift
Grip the connector and lift from the source fixture.
- 04
Controlled transfer
Represent a controlled approach and small alignment steps towards the current target.
- 05
Final check and record
Lower and release the connector; compare the seating image with the motion record.
Related applications



Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.