

Robotic picking of translucent plastic trays from stacks
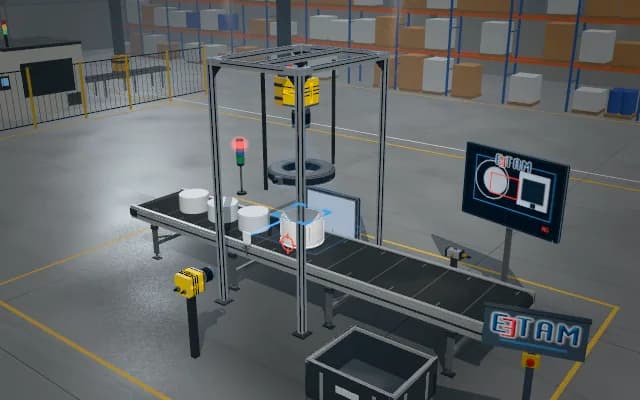
The upper tray in the stack is located from edge and height data. The robot descends to the selected grasp point; it places a single tray on the transport belt, while a detected double tray blocks the pick.
The validated tray grasp pose is sent to robot control. A double layer or insufficient edge data inhibits picking and flags the stack on the operator display.

- 01 Stack
- 02 Depth
- 03 Match
- 04 Enable
- 05 Transfer
The upper tray rim enters the imaging field.
- Detected layers
- —
- Rim height
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
Depth data from a translucent tray can be discontinuous. Nested edges are close together; mistaking two stuck trays for one can disrupt the grasp.
Solution approach
An overhead 3D camera suitable for transparent surfaces extracts the tray rim and height. Valid edges are matched with the tray model; the grasp plane and layer spacing are checked. Once a single layer is confirmed, the vacuum robot picks and places the tray.
Process steps
- 01
Stack
The upper tray rim enters the imaging field.
- 02
Depth
Rim and height samples are extracted.
- 03
Match
Layer spacing is checked against the tray model.
- 04
Enable
A single layer enables the pick.
- 05
Transfer
The robot places a single tray and waits for a double layer.
Related applications



Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.