

Metal-part picking from a mixed bin using 3D pose
Pose, grip confirmation and placement result stay linked to one candidate. Detecting an occluded, unreachable or colliding candidate never constitutes motion permission; it awaits reassessment. Calibration, grip and PLC sequence are animated as an illustrative simulation.
Pose, grip confirmation and placement result stay linked to one candidate. Detecting an occluded, unreachable or colliding candidate never constitutes motion permission; it awaits reassessment.
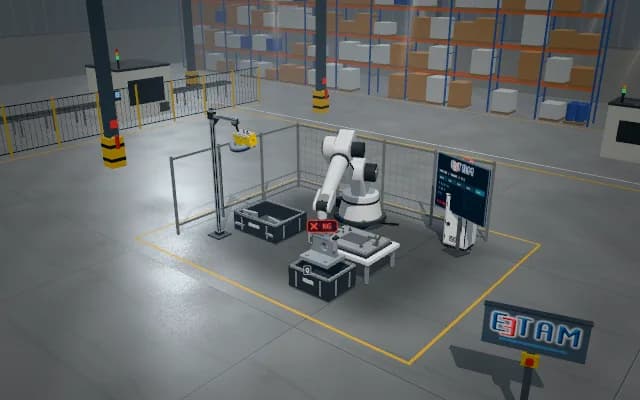
- 01 Image and source
- 02 Pose and plan
- 03 Grip and lift
- 04 Transfer
- 05 Release and final check
Scan visible bin surfaces and mark one metal bracket candidate.
- Illustrative pose offset
- —
- Illustrative grip confirmation
- —
- Completed transfers
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
Metal brackets overlap and rest at different angles in a bin. Finding a visible surface does not establish an executable grasp path; neighbours, bin walls and gripper volume need joint consideration.
Solution approach
Generate a pose and grasp candidate from visible 3D bracket surfaces. Show reach, approach and bin-neighbour checks separately in simulation. Grip a usable candidate, lift clear of the bin, carry to the fixture and release in orientation; verify final placement.
Process steps
- 01
Image and source
Scan visible bin surfaces and mark one metal bracket candidate.
- 02
Pose and plan
Represent reach, approach and collision checks for the pose and grip point.
- 03
Grip and lift
Close the gripper on the validated surface and lift the bracket away from neighbouring parts.
- 04
Transfer
Carry the bracket attached to the gripper clear of the bin towards the fixture.
- 05
Release and final check
Lower and release into the fixture; orientation and presence checks complete the transfer.
Related applications


Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.