

Casting & Metalworking
Industry overview
A casting passes through surface, silhouette and bore inspection in sequence. Pore indications, diameter and thread rings are evaluated at three stations on the same line.
surface inspectionsilhouette gaugingthread inspection
16
Applications
Casting & MetalworkingILLUSTRATIVE SIMULATION

- 01 Porosity
- 02 Diameter
- 03 Thread
—
The machined surface is imaged under a dome light.
- Pores
- —
- Diameter
- —
- Thread rings
- —
Casting & Metalworking
Applications
Casting & Metalworking07
 Artificial intelligence
Porosity detection on machined cast surfaces
dome lightingpore segmentationgasket region Artificial intelligence
Void analysis in X-ray images of castings
radiographyvoid segmentationcritical-region mask
Diameter and length gauging of turned parts from silhouette
telecentric imagingbacklightdiameter and length
Thread inspection of screws and tapped holes
bore imagingring patternthread presence
Contour and hole check of blanked parts at press exit
backlit silhouettenominal contourhole check
Bend angle and spring-back measurement on sheet metal
laser profilingbend anglespring-back
Wear inspection of spot-welding electrode caps
tip silhouetteend-face imagingwear gauging
Research-informed advanced applications08
 Artificial intelligence
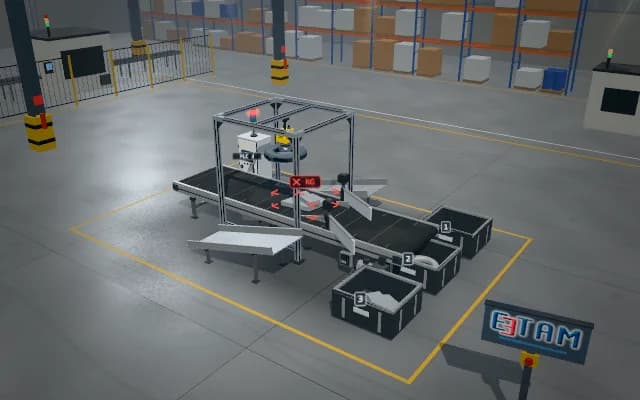
Three-output sorting of mixed metal scrap by shape class
shape classthree outputsposition tracking Artificial intelligence
Robotic nesting of forgings by pose and orientation
3D poseoriented nestingrobot rotation
3D burr-volume measurement on machined groove profiles
3D profileburr volumereference surface Artificial intelligence
Casting texture grades with uncertain-sample handling
research-backed conceptraw image / analysis separationclass confidence gate Artificial intelligence
Casting-pore masks and regional area fraction
research-backed conceptraw image / analysis separationpixel / instance mask Artificial intelligence
Local anomaly inspection learned from normal machining textures
research-backed conceptraw image / analysis separationnormal-only local score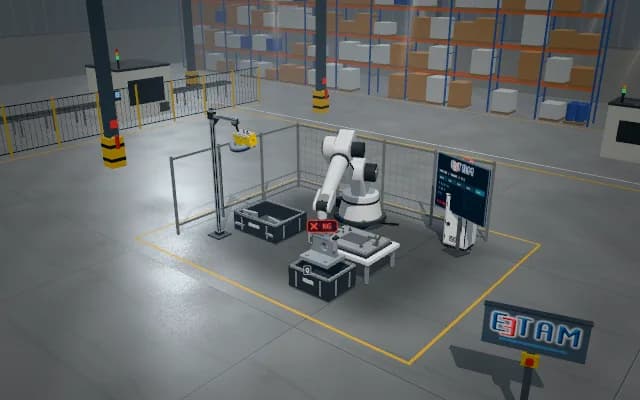 Artificial intelligence
Metal-part picking from a mixed bin using 3D pose
vision-located targetgrip confirmationphysical transfer Artificial intelligence
Grip-pose and reach verification from a 3D point cloud
current imagecoordinate associationcontrolled motion
Requirement-led project concepts01

Scenes are illustrative simulations; they are not customer references or performance guarantees.
Vision system design
Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.