

Empty-bottle and foreign-object check in returnable crates
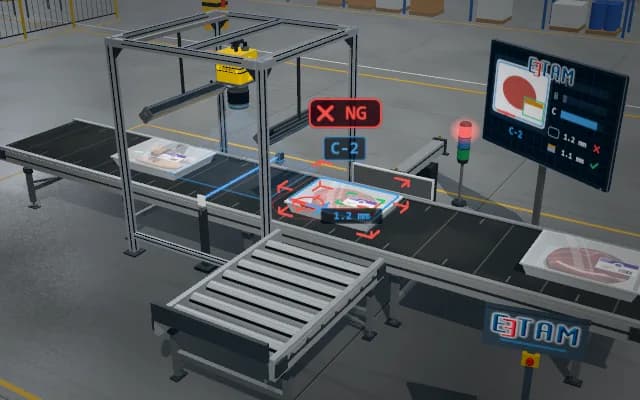
The returned crate is imaged from above before the robot. Bottle-mouth heights and arrangement are checked alongside a colour image; a crate with missing or capped bottles or foreign objects is diverted to the side line.
Presence, height and defect data for each slot are sent to the PLC. A non-conforming crate is pushed onto the side line before reaching the unloading robot; the slot matrix is retained on the display.

- 01 Infeed
- 02 Trigger
- 03 Acquire
- 04 Analyse
- 05 Decision and separation
The product is carried into the inspection station.
- Upright bottle count
- —
- Mouth-height deviation
- —
- Flagged slots
- —
Scenes are illustrative simulations; they are not customer references or performance guarantees.
Need
Crate walls obscure bottle bodies; an empty slot, a lying bottle and a dark foreign object can look similar in the same region. Different bottle types change mouth height.
Solution approach
Overhead 3D scanning and an area camera share a gantry. Mouth height and presence are checked in a slot matrix aligned to the crate frame; the colour image separates caps and foreign objects. The map and slot decisions are combined on one display.
Process steps
- 01
Infeed
The product is carried into the inspection station.
- 02
Trigger
The photo-sensor reports the product position.
- 03
Acquire
The crate is scanned under the gantry with 3D and colour imaging.
- 04
Analyse
Mouth height, caps and foreign objects are checked on the slot matrix.
- 05
Decision and separation
The result is sent to the display and PLC; a non-conforming product is separated.
Related applications




Let us assess your application together
We test your sample in our laboratory and report on resolution, optics and lighting selection.